Autonomous Maze Navigation & Retrieval Robot
A zero-turn autonomous robot that solves an unknown maze, retrieves an object, and computes the shortest route out.
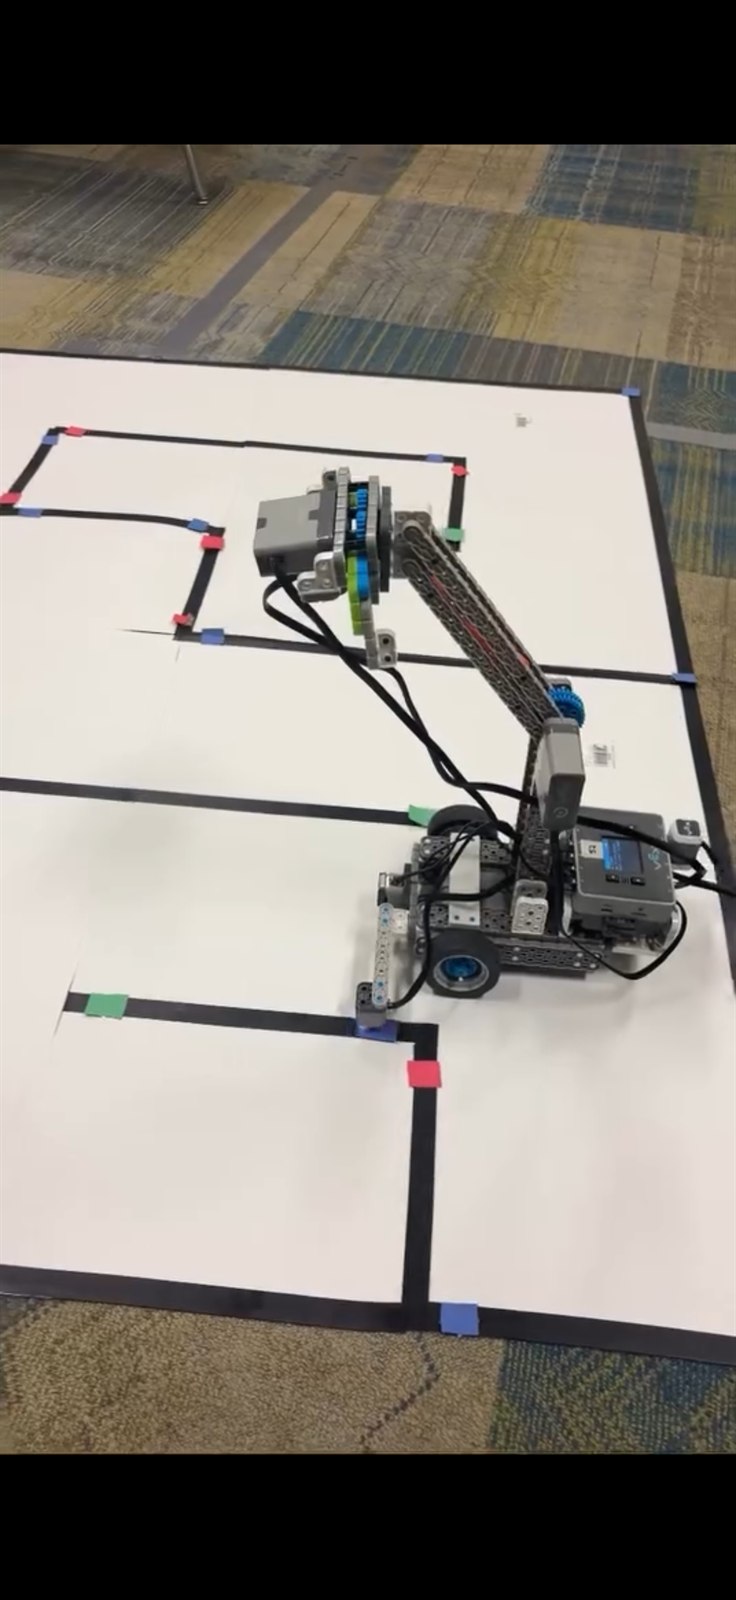
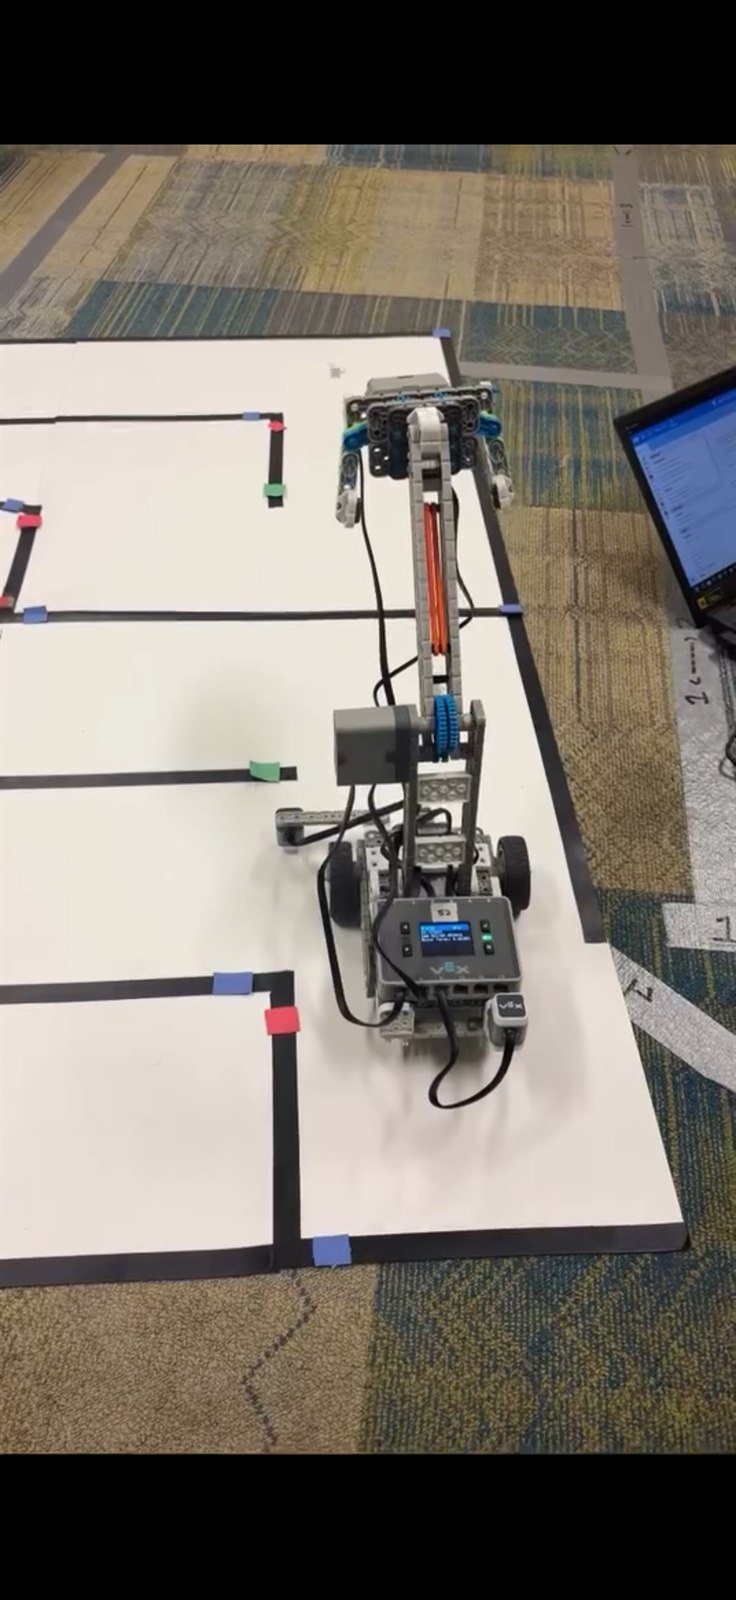
An end-to-end autonomous ground robot built to explore an unknown maze, retrieve a target object, and return along the optimal path, with no remote control and no prior map.
- Designed a 3-wheel zero-turn drivetrain with a geared, rubber-band claw for precise object retrieval.
- Fused optical, gyro, and distance sensors for Left-Hand-Rule maze solving and dead-reckoning localization.
- Engineered a path-optimization algorithm that logs coordinates during exploration and computes the shortest exit route.
01The problem
The robot starts blind inside an unknown maze. It has to explore, find and grab a target object, and get back out reliably and quickly. That means solving localization, motion control, and path optimization on a resource-constrained microcontroller in real time.
02Approach
I paired a Left-Hand-Rule exploration strategy with multi-sensor dead reckoning: an optical sensor and gyro track heading and travel while a distance sensor reads walls. Coordinates are logged continuously so the robot builds an internal map as it goes.
03Result
Once the object is retrieved, a path-optimization routine collapses the logged exploration path into the shortest valid exit route, so the return trip skips every dead end the robot hit on the way in.
Want to talk through how I built this?